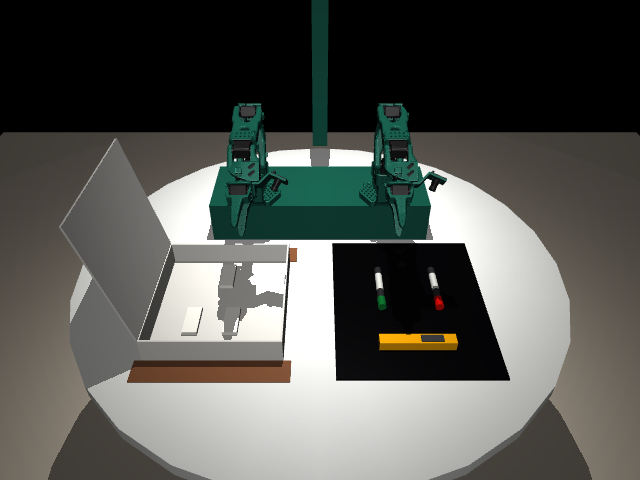
Recorded MuJoCo preview
No robot connection. Replay and camera exploration are available now.
Connect your own Haller service
GitHub Pages hosts this interface. Your local companion supplies cameras, measured joints and the existing guarded FLUX runner.
./scripts/research_ui.sh
To launch FLUX prompts too, add --profile PATH_TO_VERIFIED_PROFILE using the current checkpoint, GPU transport and camera mapping for your arm. Hardware execution stays gated by fresh telemetry, verified units and explicit manual engagement. Setup details ↗
--profile PATH_TO_VERIFIED_PROFILE